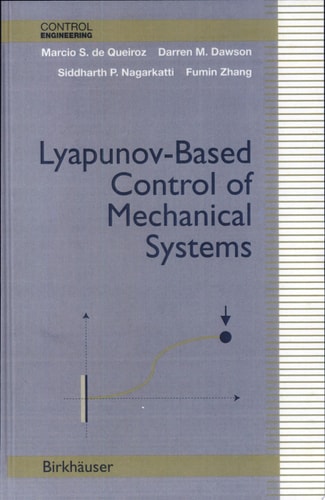
Lyapunov-based Control of Mechanical Systems
0
0
As an Amazon Associate and affiliate partner, Menrva Books earns from qualifying purchases. Learn more
Author Description
This is a new text/reference on advanced nonlinear controllers for mechanical systems that are based on a Lyapunov-type design and analysis methodology. The presentation illustrates, in a unified framework, how recent Lyapunov-based techniques can be used to solve a variety of nonlinear control problems for mechanical systems. This new book provides a thorough discussion and presentation of advanced, Lyapunov-based nonlinear controllers for mechanical systems. Researchers and professionals in the areas of systems, controls, and robotics will benefit from the new control design strategies, most of which are supported by experimental verification.--BOOK JACKET.
Menrva's Summary
THE THESIS
This text explores advanced nonlinear controllers for mechanical systems, focusing on Lyapunov-based design and analysis. The book presents recent Lyapunov-based techniques within a unified framework, demonstrating their application to diverse nonlinear control problems in mechanical systems. It is intended for researchers and professionals in systems, controls, and robotics, offering new control design strategies, many of which are supported by experimental verification.
THE SCOPE MAP
- Discussion of advanced, Lyapunov-based nonlinear controllers for mechanical systems.
- Unified framework for applying Lyapunov-based techniques.
- Solutions to a variety of nonlinear control problems in mechanical systems.
- New control design strategies for systems, controls, and robotics.
- Presentation of experimental verification for many of the proposed strategies.
THE AUTHORITY PERSPECTIVE
The book is presented as a new text and reference for researchers and professionals in systems, controls, and robotics. Its focus on advanced Lyapunov-based nonlinear controllers for mechanical systems suggests a technical and specialized audience. The inclusion of experimental verification for control design strategies indicates a practical and applied approach to theoretical concepts.
Page Count:
316
Publication Date:
2012-01-01
ISBN-10:
1461271088
ISBN-13:
9781461271086
Non-Fiction
Science
Robotics
Control systems